
AlpaSim
Open-source modular research simulator for closed-loop testing of end-to-end autonomous driving policies.
At a Glance
AlpaSim core simulator is open source under the Apache License 2.0, with a no-charge, royalty-free license grant.
Engagement
Available On
Alternatives
Listed Oct 2026
About AlpaSim
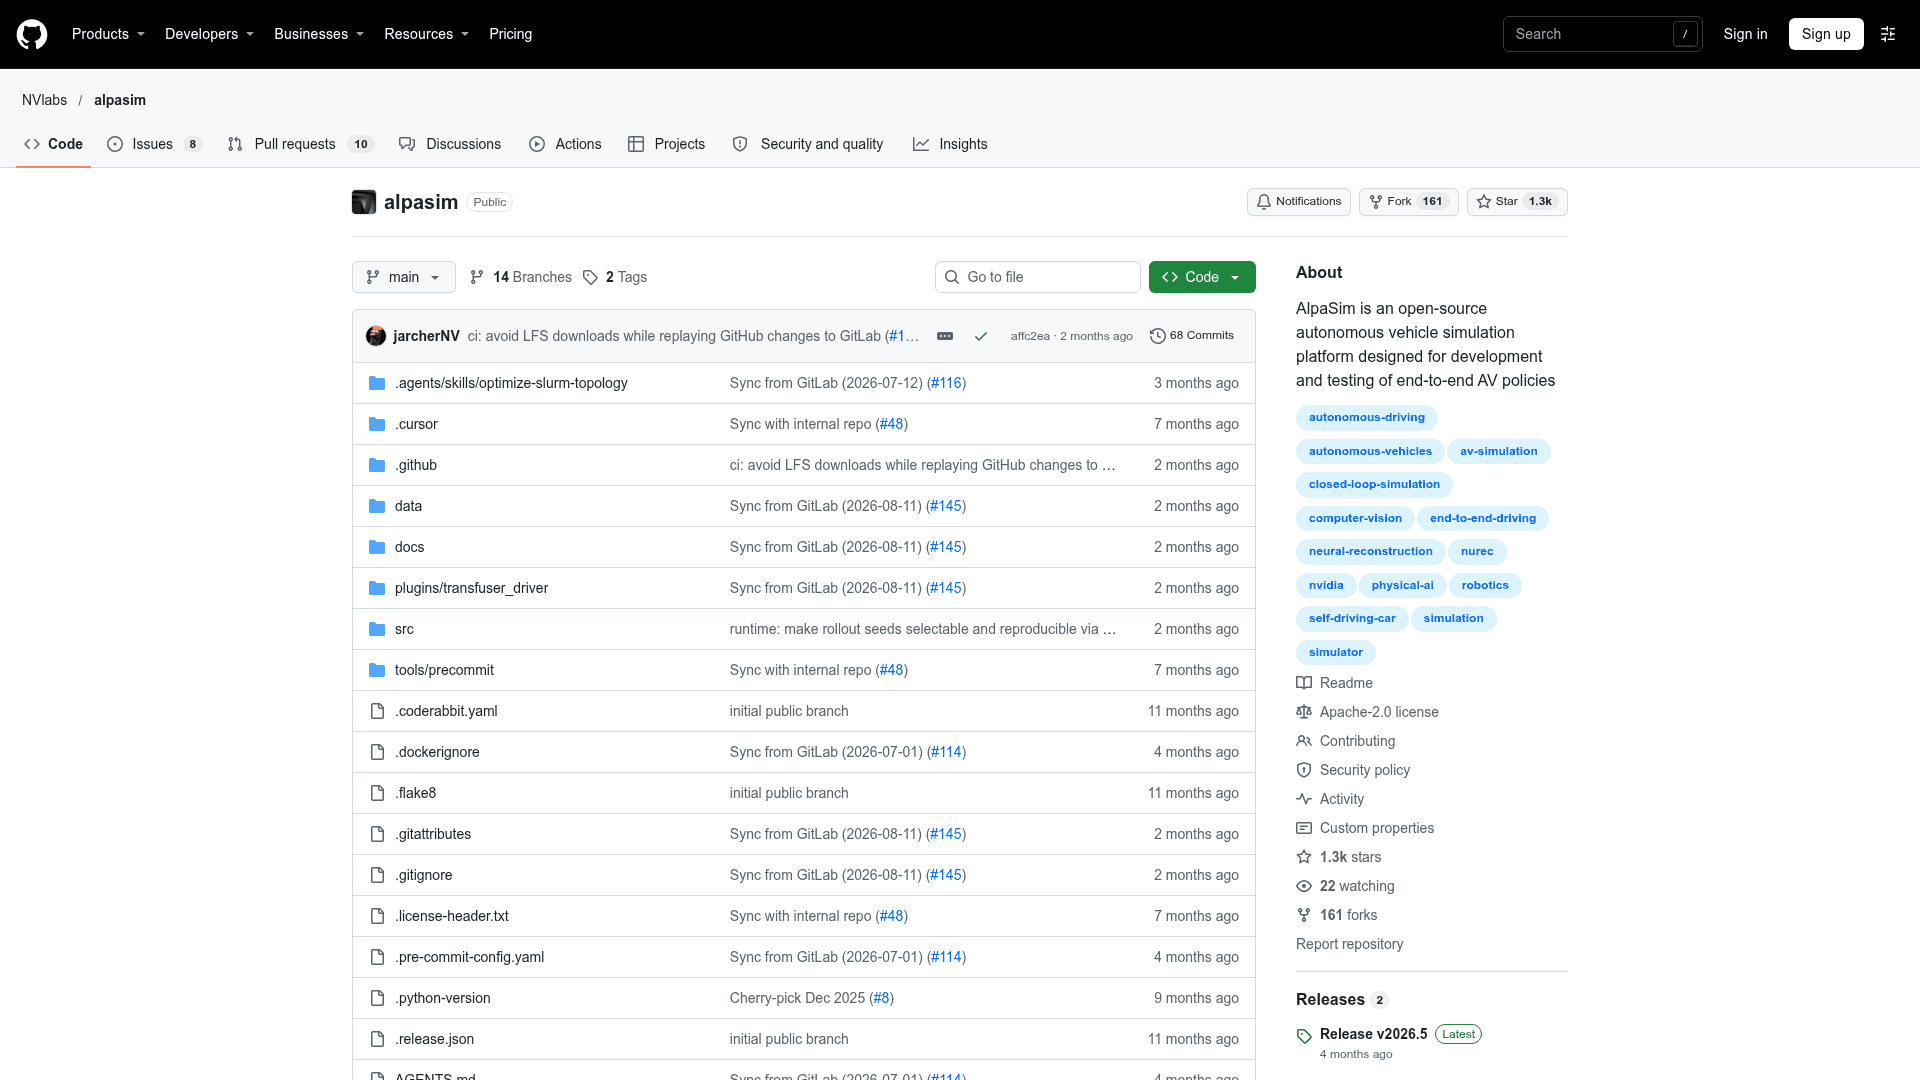
AlpaSim is an open-source autonomous vehicle simulation platform from NVIDIA research (NVlabs) for developing and testing end-to-end AV policies. It simulates sensor data, vehicle dynamics, and traffic scenarios in a closed loop. The latest listed release is v2026.5, and the code is licensed under Apache 2.0.
What It Is
AlpaSim is a Python-based research simulator that lets users run driving policies in a closed-loop testbed. Documented use cases include algorithm validation, safety analysis of edge cases, performance benchmarking and regression testing, and debugging complex driving behavior. Components communicate through a modular gRPC interface, so researchers can swap in custom implementations.
Rendering and Sensor Fidelity
The renderer is a pluggable service. NuRec is supported by default, and OmniDreams video-model rendering is available through FlashDreams. Camera feeds have configurable field of view, resolution, and frame rate, and the simulator models sensor noise and environmental conditions. Stateful video-model rendering is aimed at better fidelity for dynamic objects and non-rigid visuals.
Supported Driving Policies
The README lists Alpamayo-R1, Alpamayo 1.5 checkpoint support, VaVAM, and a provisional Transfuser (LTFv6) integration. A plugin system supports extending AlpaSim with custom models, configs, and tools.
Deployment and Setup
A microservices architecture allows individual components to be scaled and supports multi-node deployments. Local runs use Docker Compose on a single machine by following the tutorial, and cluster deployment uses SLURM tooling in the repository. Documentation covers onboarding, operations, Prometheus telemetry, the ASL log data pipeline, and manual keyboard control of the ego vehicle. Sample scenes are available through a Hugging Face NuRec dataset.
Community Discussions
Be the first to start a conversation about AlpaSim
Share your experience with AlpaSim, ask questions, or help others learn from your insights.
Pricing
Open Source (Apache 2.0)
AlpaSim core simulator is open source under the Apache License 2.0, with a no-charge, royalty-free license grant.
- Licensed under Apache License 2.0
- Pluggable renderer service with NuRec support
- Modular gRPC interface
- Microservices architecture with multi-node deployment support
- Supports Alpamayo-R1, Alpamayo 1.5, VaVAM and Transfuser driving policies
Capabilities
Key Features
- Closed-loop simulation of end-to-end AV policies
- Pluggable renderer service with NuRec and OmniDreams/FlashDreams support
- Configurable camera field of view, resolution, and frame rate
- Sensor noise and environmental conditions
- Modular gRPC interfaces for swapping components
- Microservices architecture with multi-node scaling
- Docker Compose local runs and SLURM cluster deployment
- Manual keyboard driver control
- Prometheus telemetry
- Plugin system for custom models, configs, and tools