
Jumper
Open-source AI toolkit for designing appearances, training motions, and creating scenes for KingKong's 22-DoF Jumper crab robot.
At a Glance
Jumper AI toolkit repository for appearance, motion and scene creation, licensed under Apache-2.0. Maintainer-owned materials only; third-party materials keep their own terms and generated outputs do not automatically inherit the license.
Engagement
Available On
Alternatives
Listed Oct 2026
About Jumper
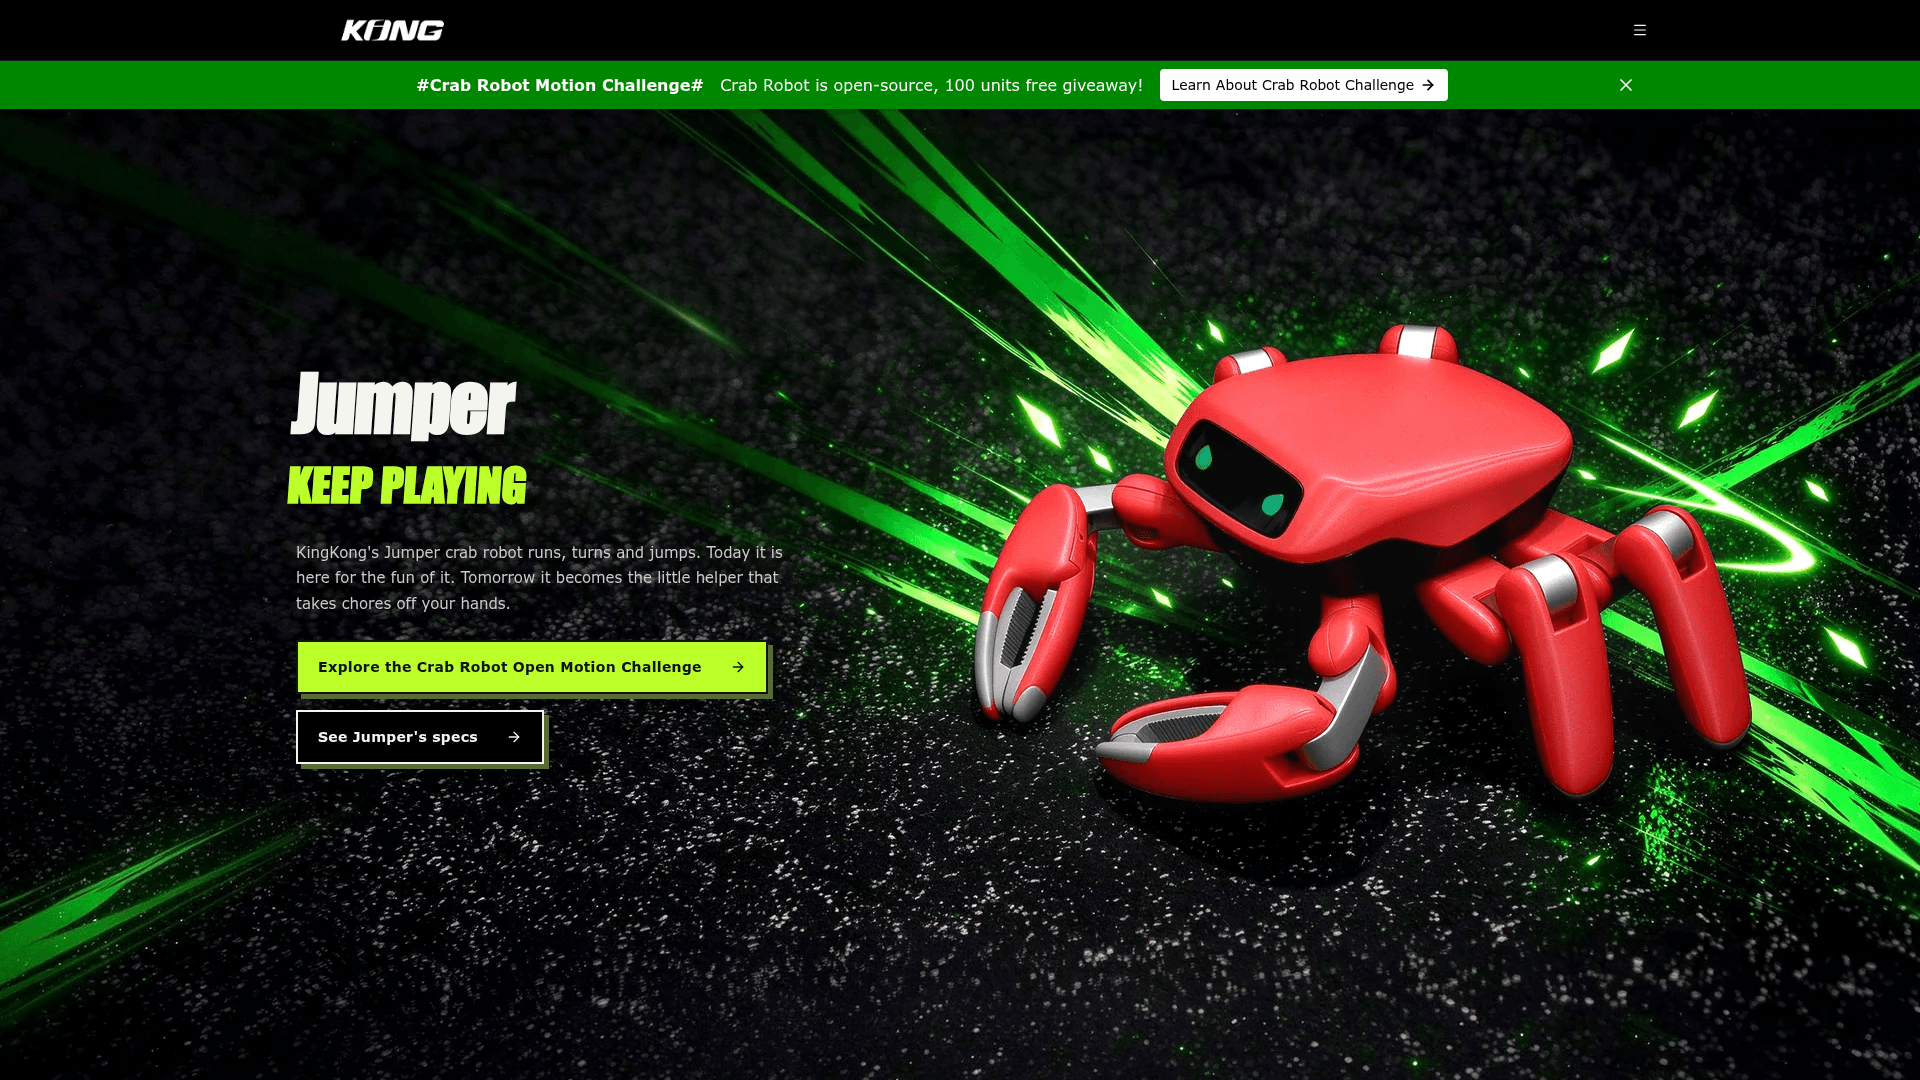
Jumper is an open-source crab robot from KingKong Technology (KingKongRobotics on GitHub). The repository serves as an AI toolkit for creating Jumper's appearance, motion, and scenes by opening it in an AI coding assistant and giving short prompts. Outputs include .skin appearance files, trained motions packaged as .app bundles, and .map scene files.
What It Is
Jumper is a 22-DoF crab robot, and this repository is its software toolkit. Users describe an idea in a sentence to an AI coding assistant, which works with the repo and the companion jumper-design repository to produce the result. The project's website also describes a browser simulator where users click the floor to move Jumper around obstacles or trigger actions.
Appearance, Motion, and Scene Workflow
- Appearance: a prompt such as designing a warm sand ranger look with coordinated body and limb colors results in an exported
.skinfile. A library of example skins is hosted in jumper-design. - Motion: a prompt such as training a stable tripod gait leads to training, replay and evaluation, then packaging as an
.app. Documented motions include walk, posture, gesture, dance, jump, and grasp. - Scene: a prompt describing terrain and objects, such as a park pump-track, exports a
.mapfile. Example maps include park, bedroom, and soccer scenes.
Training and Packaging
The repository documents a training tutorial covering motion training, replay and policy export, plus a Colab guide for GPU training with checkpoint backup, resume, ONNX export, and MP4 simulation replay. Motion bundles package trained motions and their controller. Training builds on mjlab, rsl_rl, MuJoCo, and MuJoCo Warp.
Hardware
The product page lists a crab-style multi-leg body of 400×400×200 with 22 tactile servos, 1.8 kg weight, top speed of at least 0.5 m/s, jump height of at least 400 mm, grasping load of 1 kg, and about two hours of battery life. The page notes specifications are subject to official product documentation. KingKong also promotes a Crab Robot Open Motion Challenge with a giveaway of 100 units.
Licensing
Maintainer-owned materials are under Apache-2.0; third-party materials keep their own terms, and generated outputs do not automatically inherit the repository license.
Community Discussions
Be the first to start a conversation about Jumper
Share your experience with Jumper, ask questions, or help others learn from your insights.
Pricing
Open Source (Apache-2.0)
Jumper AI toolkit repository for appearance, motion and scene creation, licensed under Apache-2.0. Maintainer-owned materials only; third-party materials keep their own terms and generated outputs do not automatically inherit the license.
- Apache License 2.0 for maintainer-owned project materials
- AI toolkit for designing appearances (.skin), training motions and creating scenes (.map)
- Motion training tutorial, Colab training, and motion bundle packaging (.app)
- Third-party materials remain under their respective terms
- Generated outputs do not automatically inherit the repository's license
Capabilities
Key Features
- Prompt-driven appearance design exporting .skin files
- Motion training with replay, evaluation and policy export
- Packaging of trained motions as .app bundles
- Scene creation exporting .map files
- Colab GPU training with checkpoint backup, resume and ONNX export
- MP4 simulation replay
- Browser simulator on the product page
- 22-DoF crab robot hardware
- Apache-2.0 open-source code